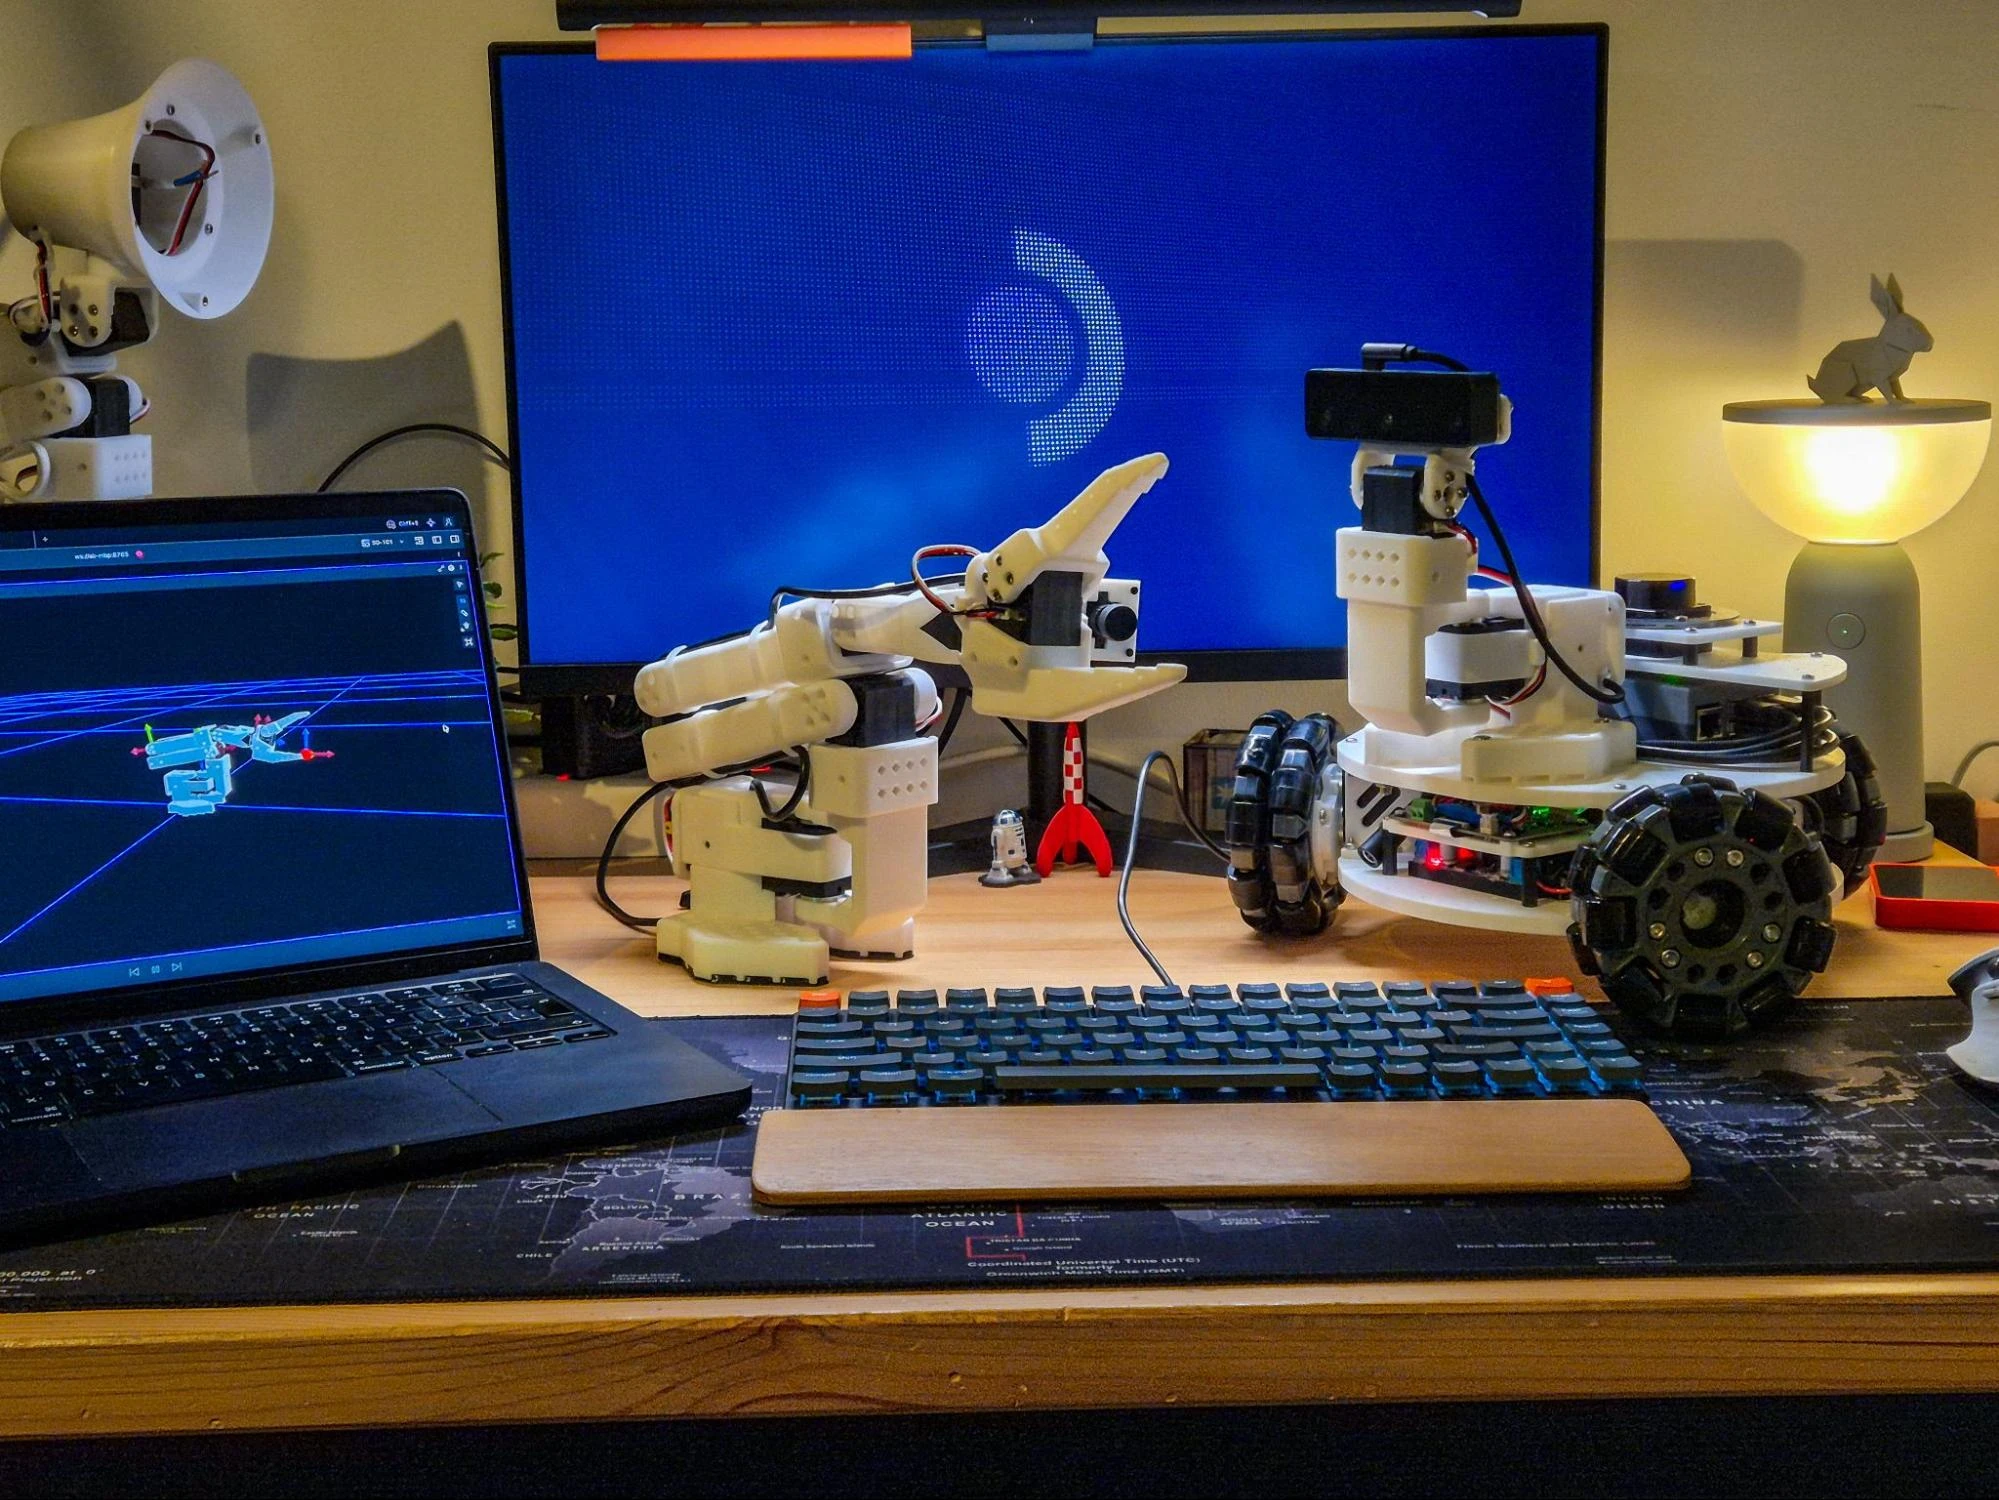
Using Foxglove as an SO-101 Simulator
Developing features using the mock mode in sts_hardware_interface

Implementing a ROS 2 service-based button control architecture for LeKiwi

Setting up the OAK-D S2 on the LeKiwi + Trying out Cloudini for the first time

Mounting and testing Seeed Studio's reSpeaker Flex on LeKiwi

Part 1: Mapping, Localization, and simple Navigation using Nav2

My first Open Hardware Summit, and a birthday I won't forget

IMU integration, EKF, and why I prefer robot_localization over alternatives